
Lightweight Smart Sense-and-Avoid Module for Low-Altitude Agricultural UAVs
Reactive, Plug-and-Play Sense-and-Avoid System for Pixhawk-Based UAVs in Precision Agriculture.
Python
ROS
A selection of my recent work
Reactive, Plug-and-Play Sense-and-Avoid System for Pixhawk-Based UAVs in Precision Agriculture.
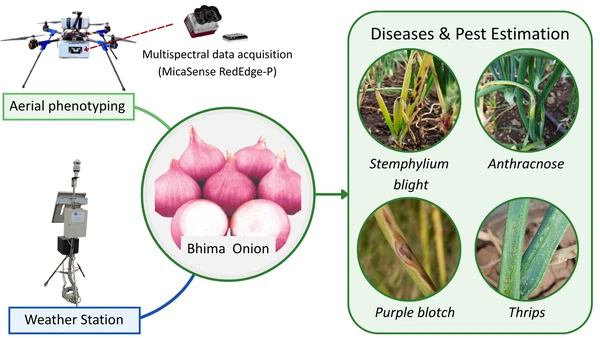
Developed a multimodal framework combining UAV multispectral imagery, weather data, and machine learning to estimate onion diseases and pest incidence.
Evaluated visual-inertial localization for UAV pose estimation in simulated agricultural environments using a downward-facing Intel RealSense depth camera.
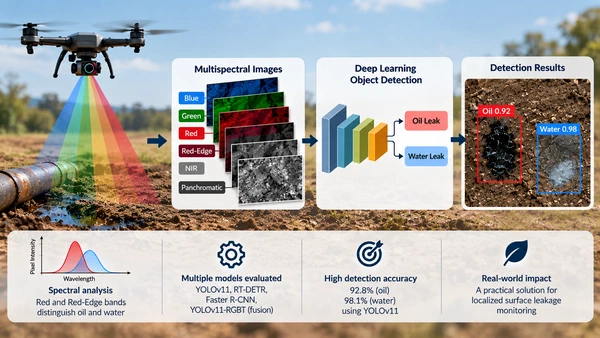
Developed a UAV-based multispectral deep learning framework for detecting and distinguishing surface oil and water leaks over soil.
Developed reactive path planning and patrolling for a team of car-like robots navigating a campus-like environment.
Designed a real-time experimental setup for studying slip and developing tactile-sensor-based grip control for a WidowX robotic gripper.
Sensor fusion and velocity control for autonomous ground robot navigation and LiDAR-based obstacle avoidance.
Developed object detection and tracking algorithms for real-time ATM surveillance and security analytics.
Technologies I use to build things
Drone Center, IIT Bombay, India
TIH Foundation for IoT & IoE, IIT Bombay, India
ARMS Lab, IIT Bombay, India
AISIGHT Video Analytics Pvt. Ltd, India
Dhristi Works, India
Singapore Institute of Neurotechnology, National University of Singapore, Singapore
Multimodal Perception Laboratory, IIIT Bangalore, India
Haryana College of Technology and Management, India
Infinite Biomedical Technologies, USA
Virginia Commonwealth University
GPA: 3.828/4.000 (Top 12% of class).
Thesis: Developed a standalone EEG-based interface for locked-in patients, enabling real-time switch control through EEG intent detection using signal processing, pattern recognition, and embedded systems.
K. J. Somaiya College of Engineering, Mumbai University
Let’s build something amazing together
Open to technical collaborations, research partnerships, and prospective opportunities. Feel free to connect or send a message.