Lightweight Smart Sense-and-Avoid Module for Low-Altitude Agricultural UAVs
Reactive, Plug-and-Play Sense-and-Avoid System for Pixhawk-Based UAVs in Precision Agriculture.
Projects in autonomous robotics, UAVs, and intelligent perception.
Reactive, Plug-and-Play Sense-and-Avoid System for Pixhawk-Based UAVs in Precision Agriculture.
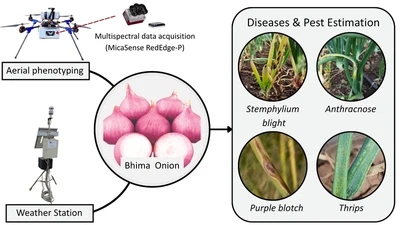
Developed a multimodal framework combining UAV multispectral imagery, weather data, and machine learning to estimate onion diseases and pest incidence.
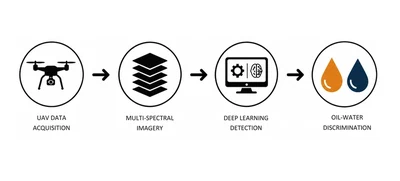
UAV multispectral imaging and deep learning for surface oil and water leak detection.
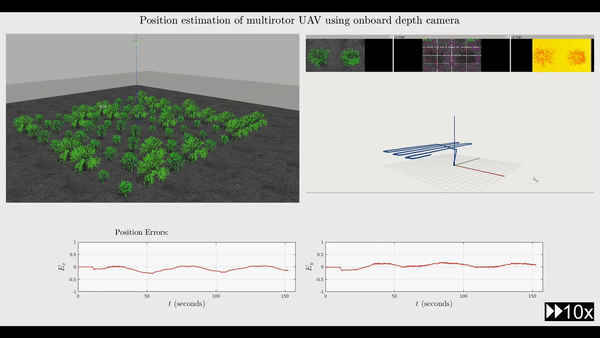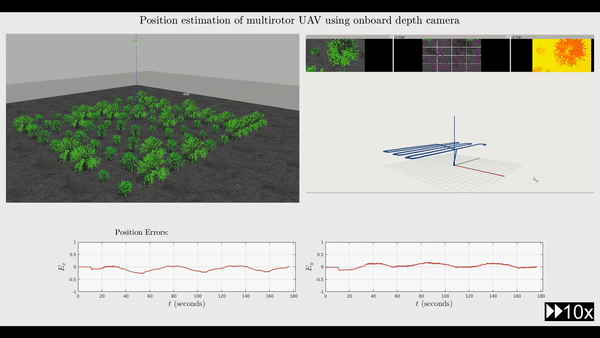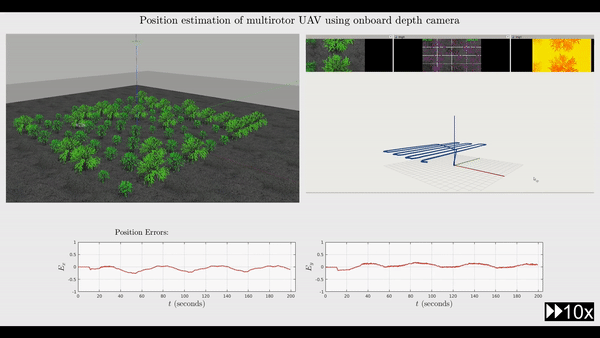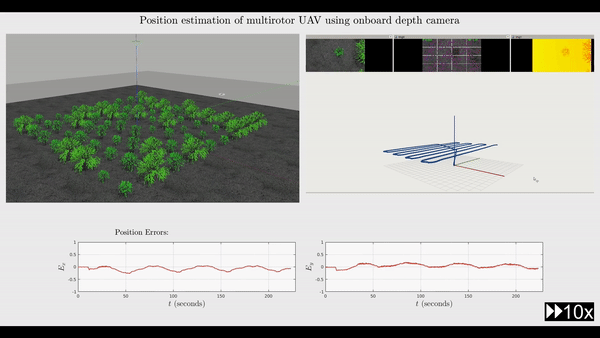
Evaluation of a feedback-based visual-inertial system across structured and unstructured simulated environments.
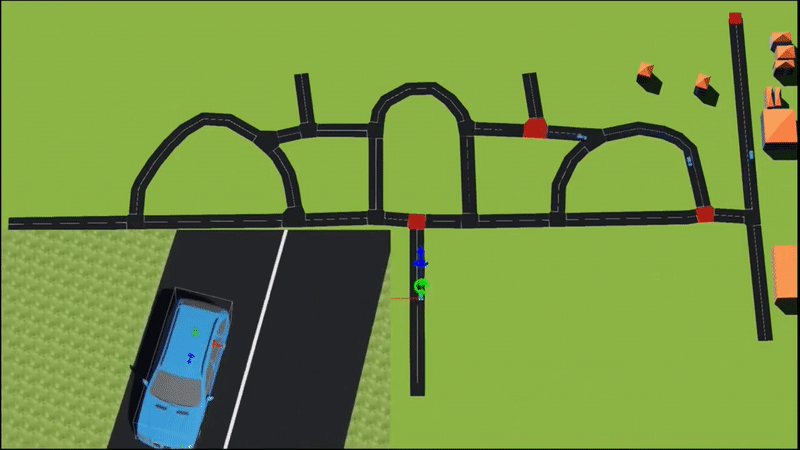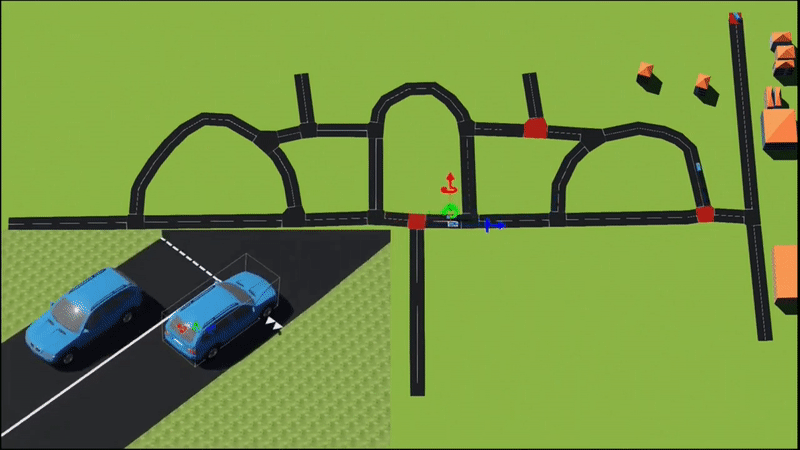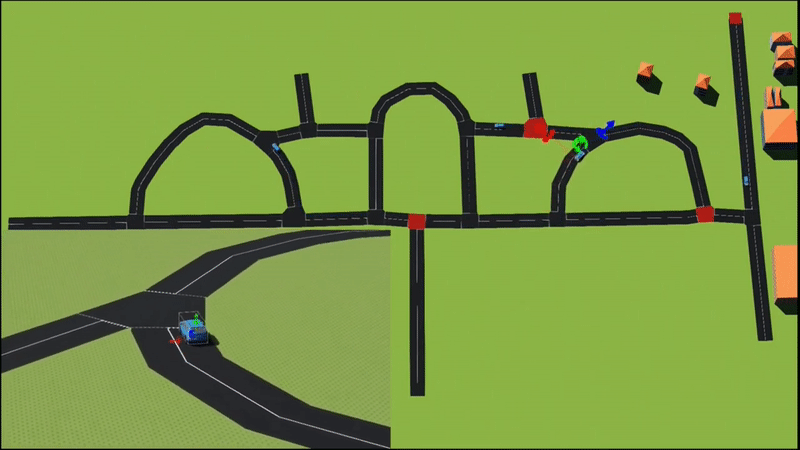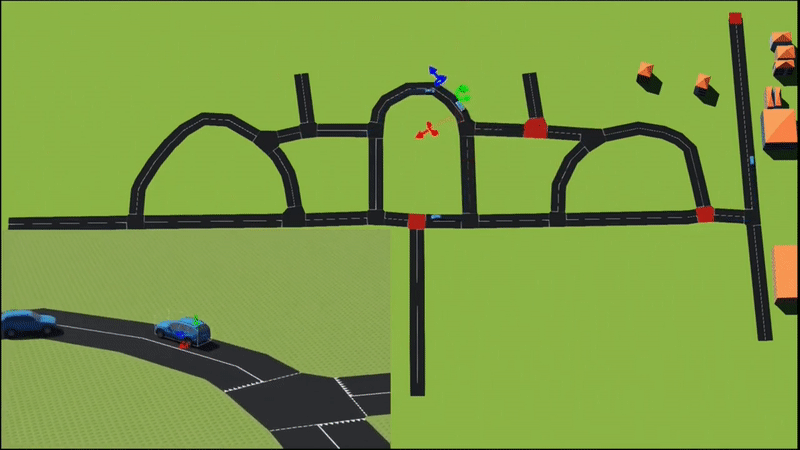
Vehicle-aware path planning and obstacle avoidance for multi-robot patrolling.
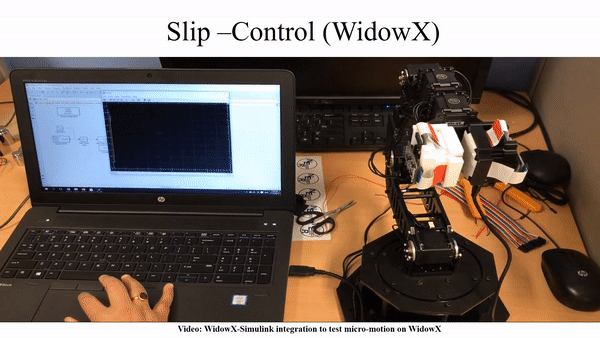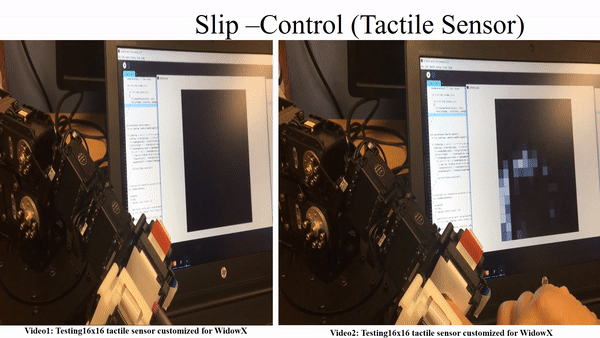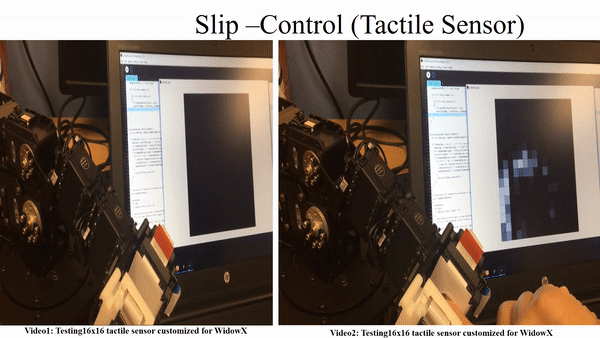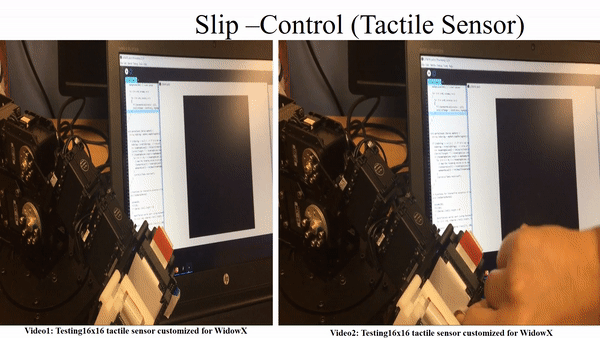
Tactile-sensor-based slip detection and grip control for robotic grasping.

Sensor fusion and LiDAR-based obstacle avoidance for autonomous ground robots.
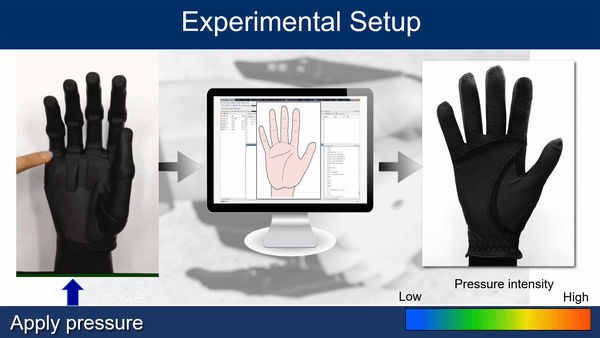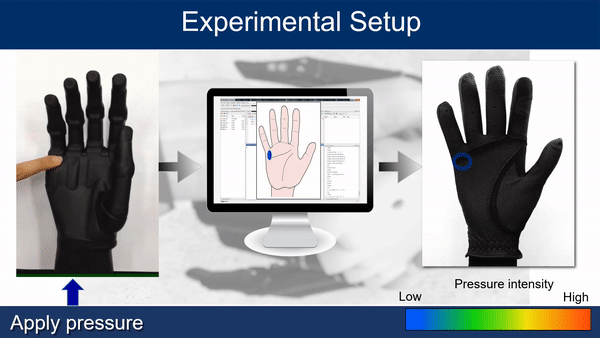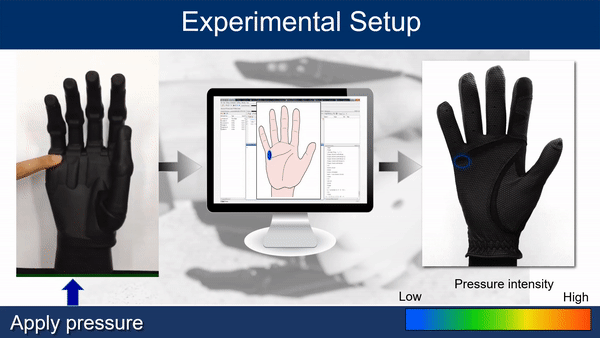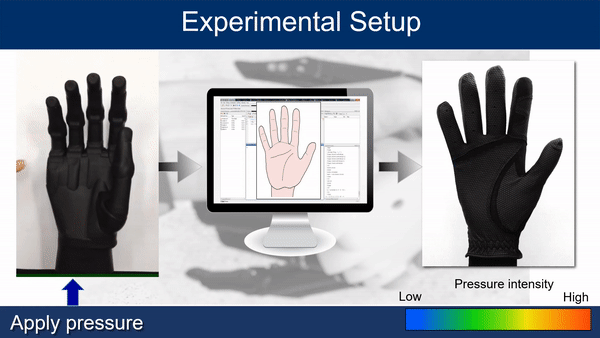
Tactile-to-haptic interface for telerobotic touch feedback.
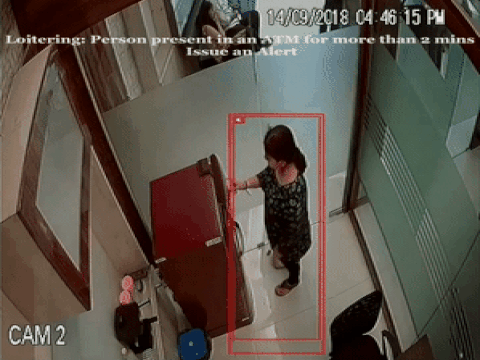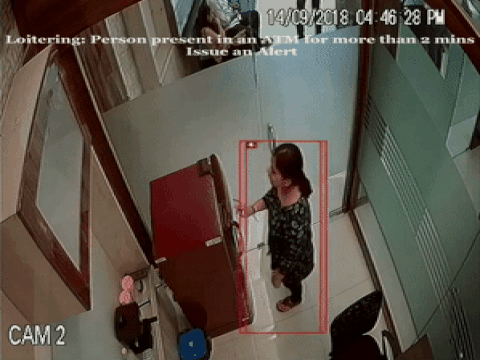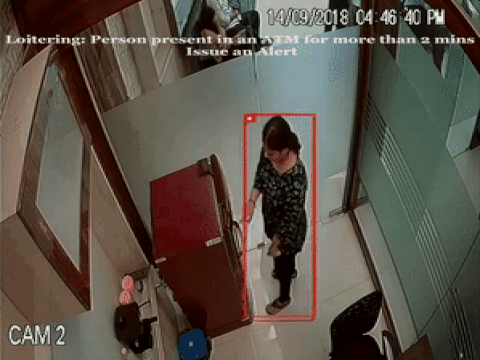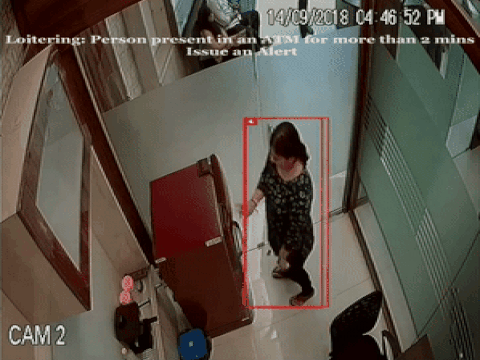
Real-time object detection and tracking for ATM surveillance.
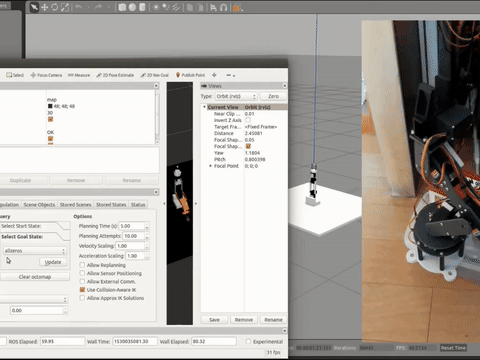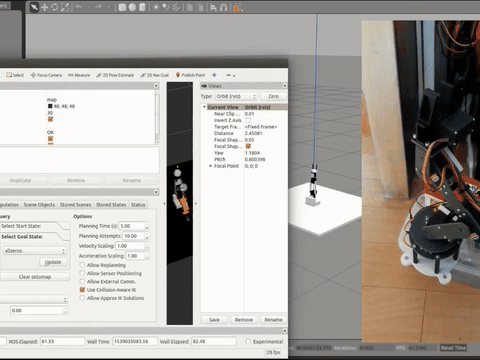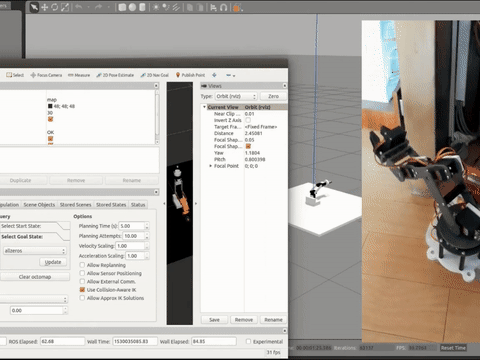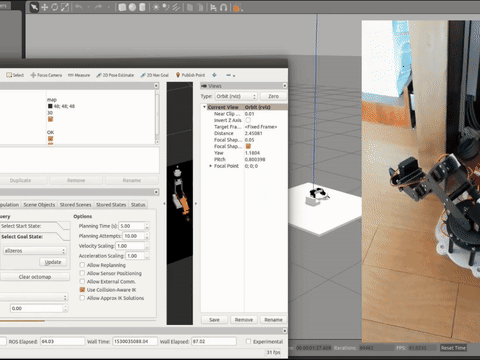
Robotic manipulator control and grasping for autonomous beach cleaning.
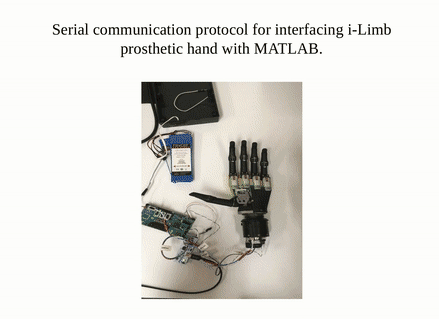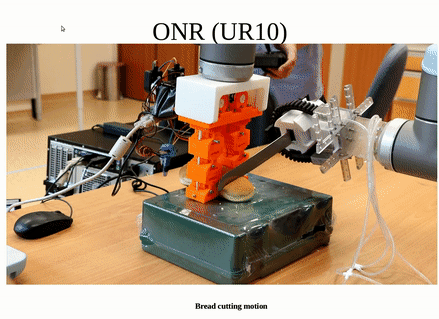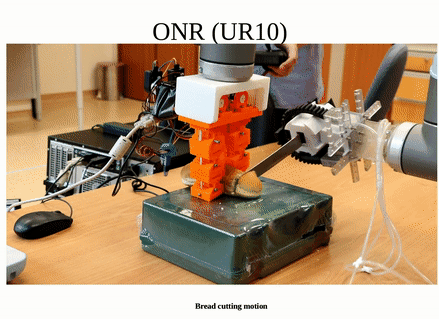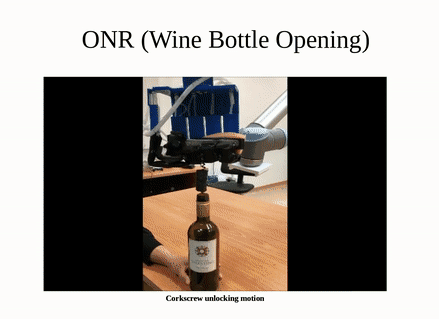
Motion planning and control for robotic manipulation and hand control.
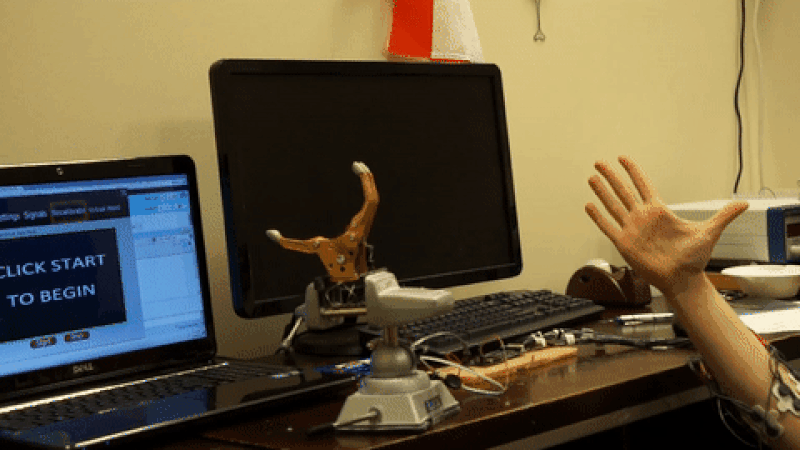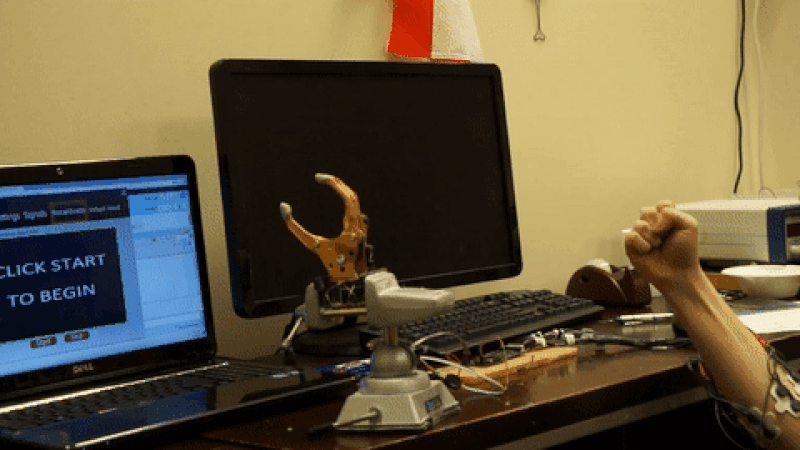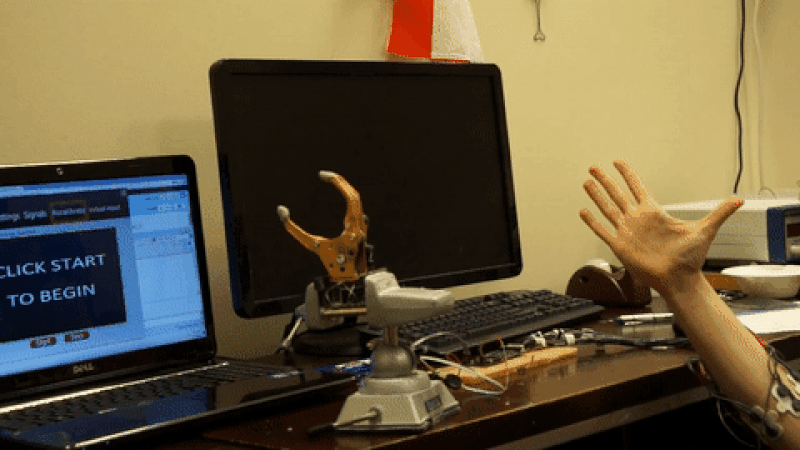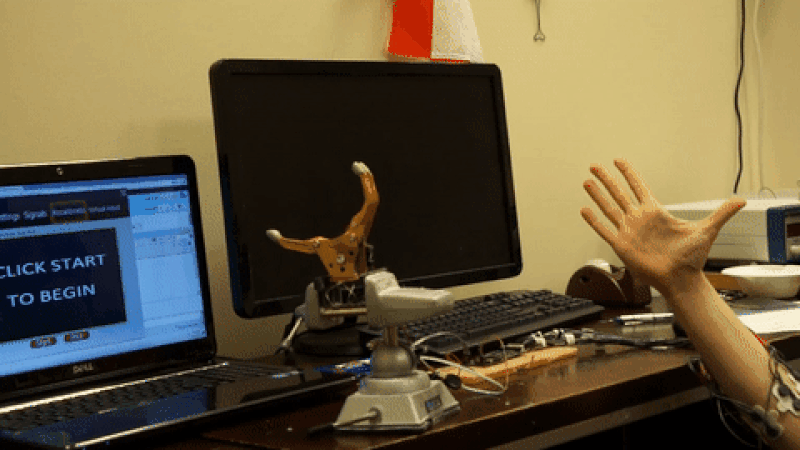
EMG-based pattern recognition for real-time prosthetic hand control.