Development of Motion Planning Algorithms for Robots
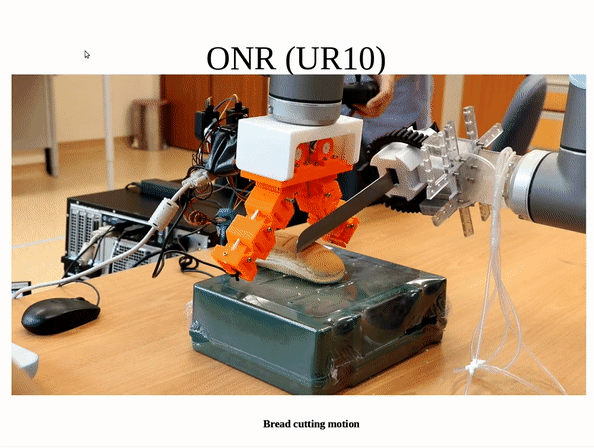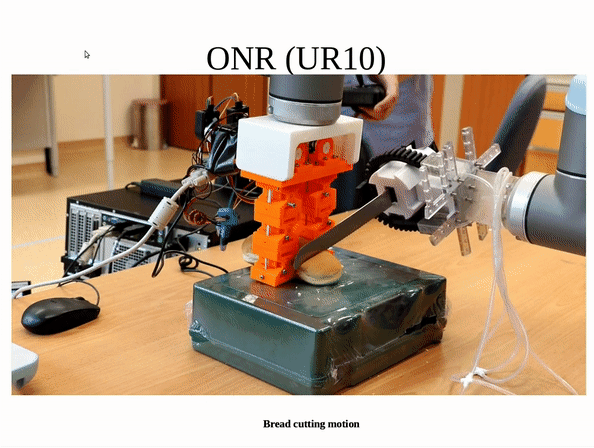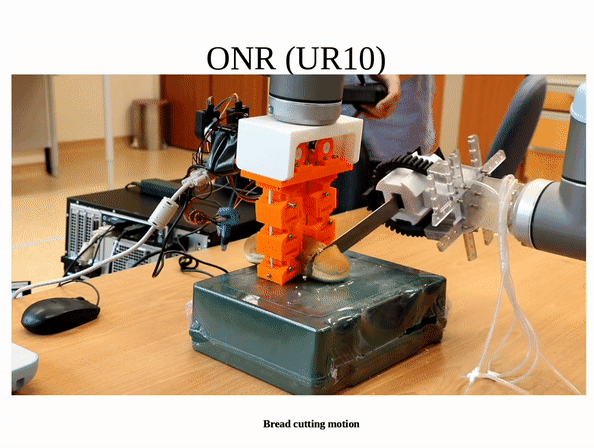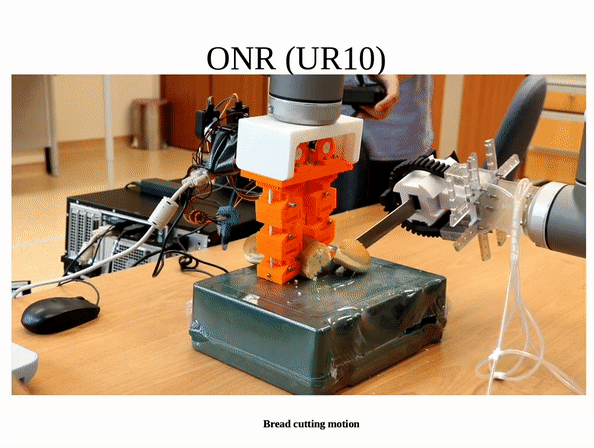
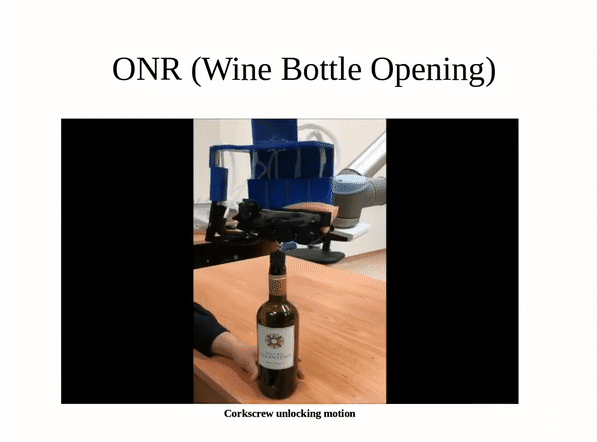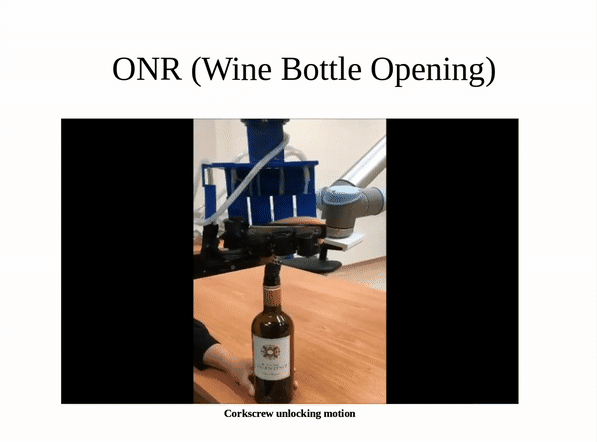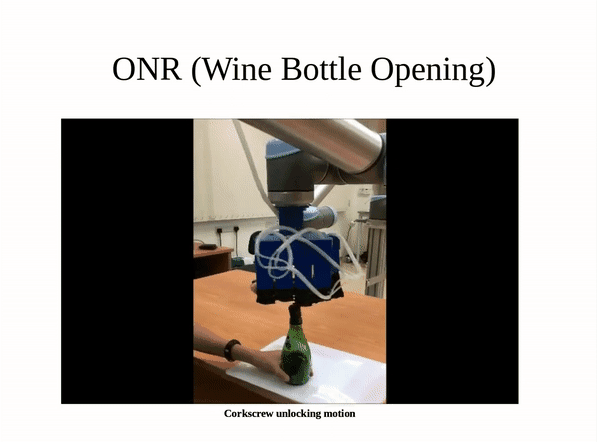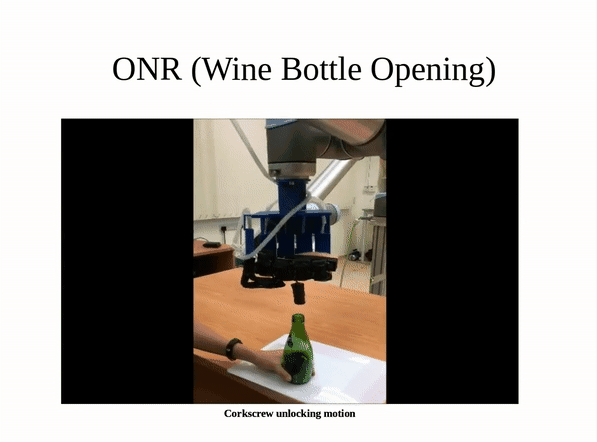
At the Singapore Institute of Neurotechnology (SINAPSE), National University of Singapore, I worked in collaboration with the Office of Naval Research Singapore on robotic manipulation for everyday tasks.
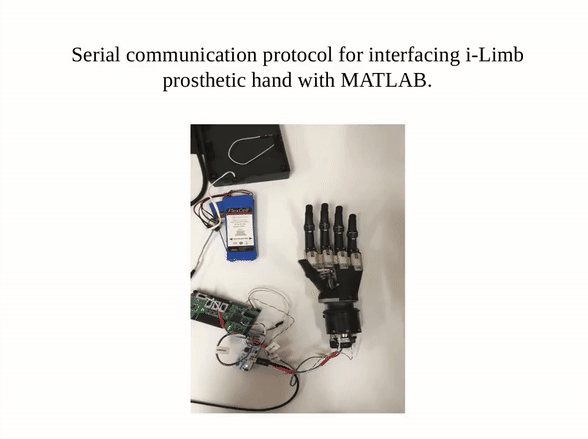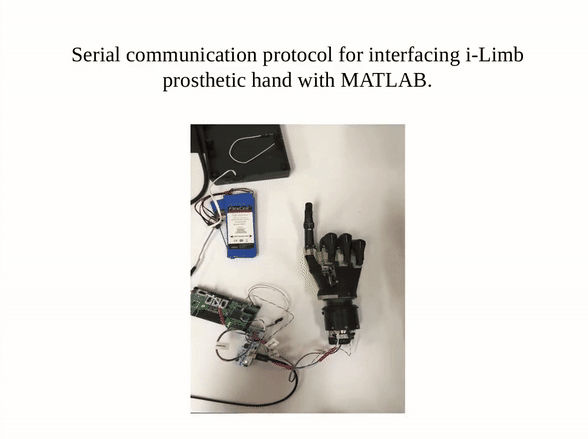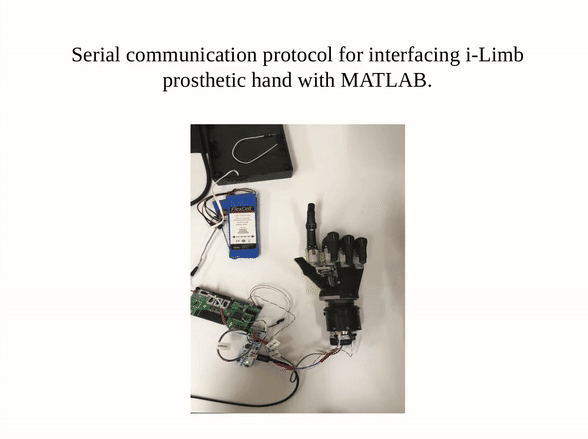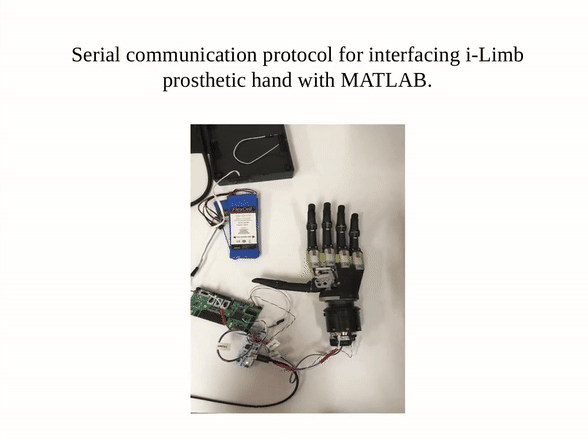
My work focused on motion planning and control for robotic manipulation. For the UR10 robot, I designed and implemented zig-zag and spiral motion trajectories for tasks including bread cutting and corkscrew opening. I also developed a programmatic interface for controlling the individual digits of an i-LIMB robotic hand.

Authors
Robotics Engineer & Researcher
Robotics engineer and researcher with 10+ years of experience specializing in robotics and computer vision.