Slip Control Experimental Setup Design
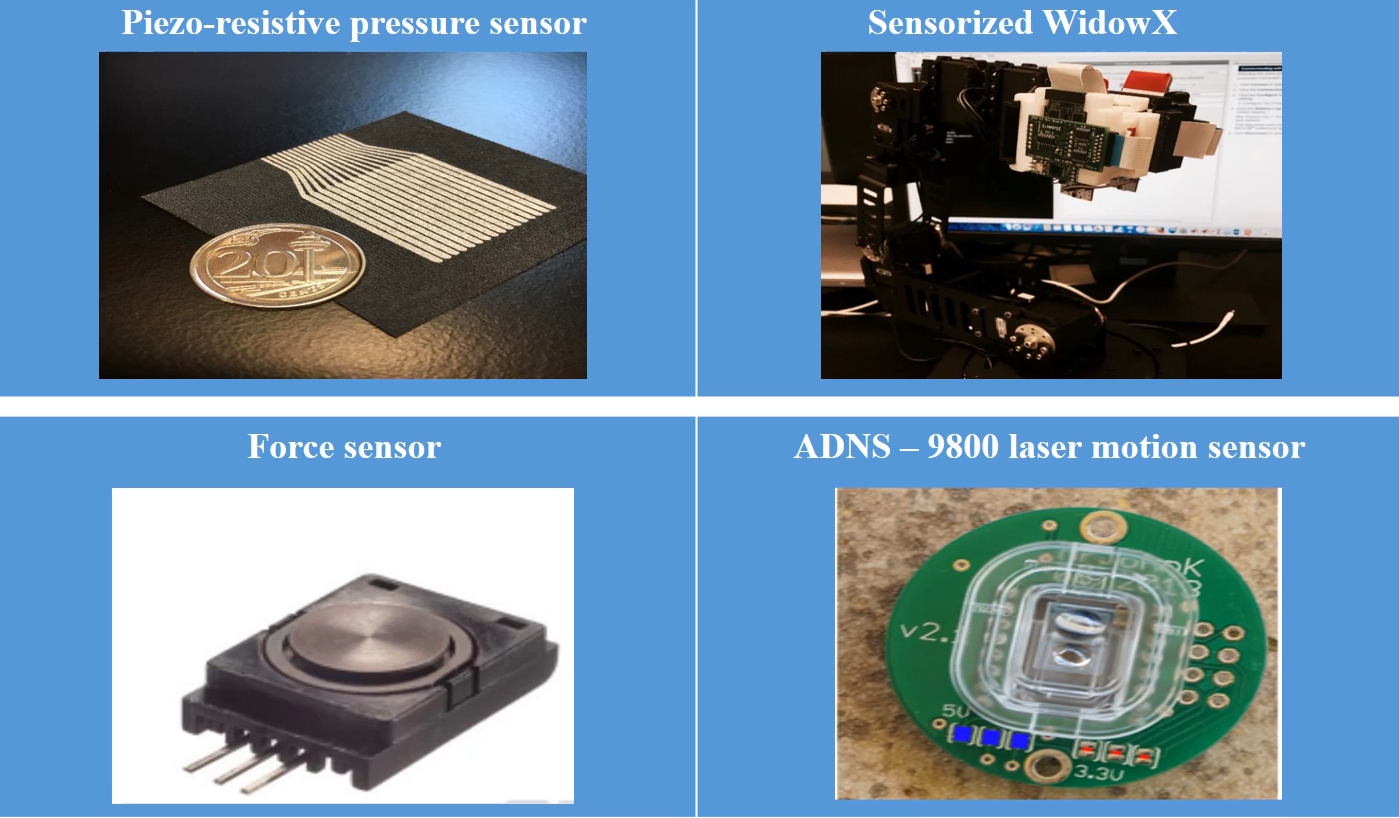
To study the occurrence of slippage when mass is added to an object gripped by a robotic end-effector, I designed an experimental setup to recreate slip conditions and evaluate friction models developed by a post-doctoral fellow.
I developed a high-density tactile sensor array designed to fit the surface of the WidowX parallel gripper and built the associated circuitry for acquiring tactile, force, and optical sensor data. The sensing system was designed to acquire data at 0.01-second intervals using Simulink.
The sensor measurements provided information about the magnitude and direction of forces acting on the gripped object, which served as inputs to the friction model and controller. I also developed an interface for controlling the robot orientation and adjusting the gripper position through micromotions at 0.01-second intervals.
These high-speed micromotions enabled the WidowX gripper to rapidly adjust its grip once a slip event was detected by the friction model and controller.
