Tactile and Haptic Glove Interface
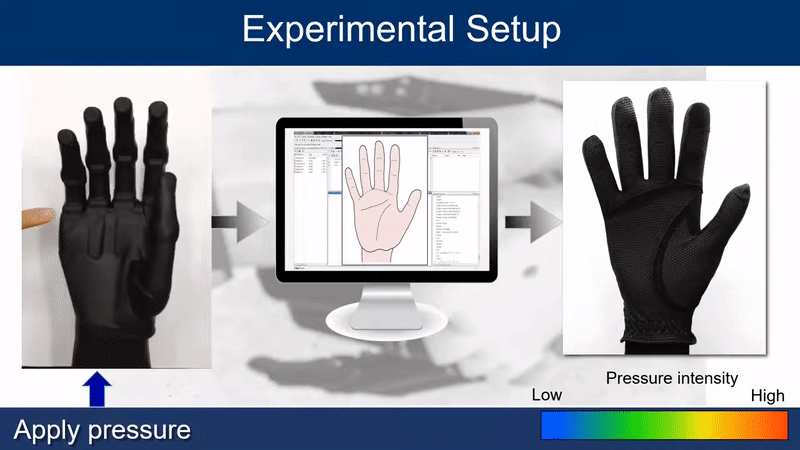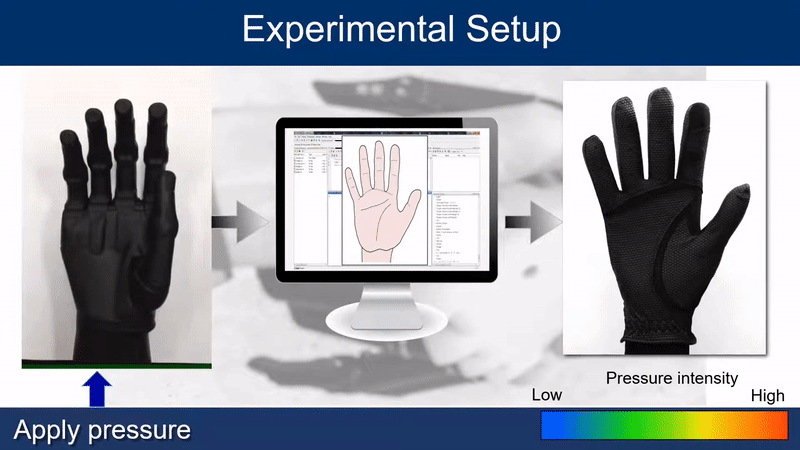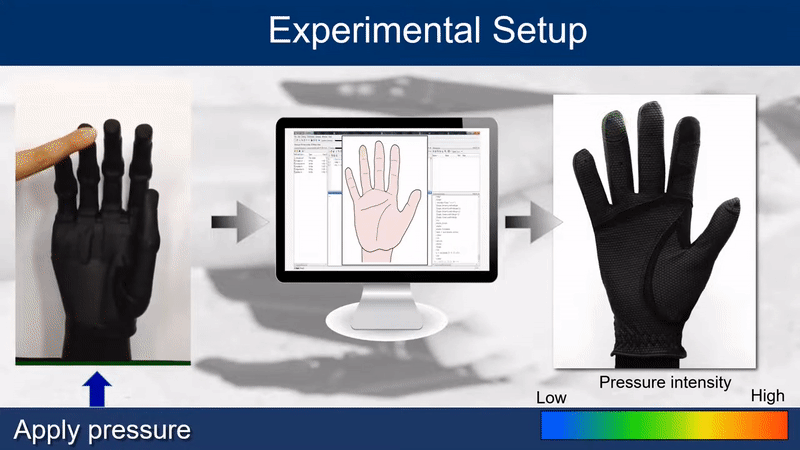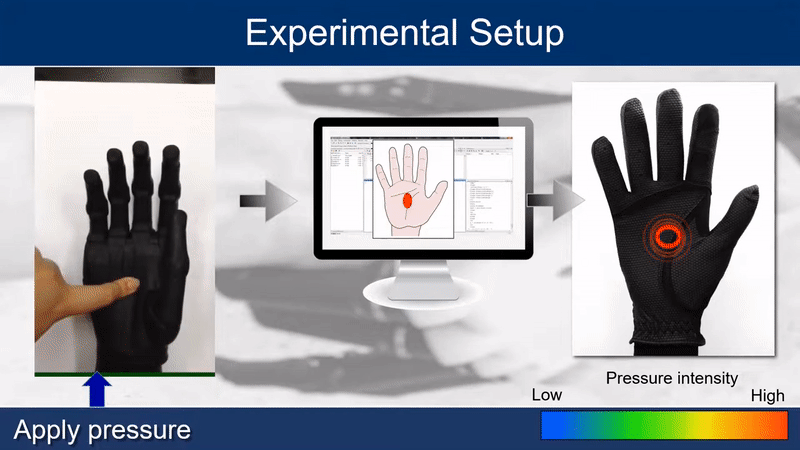
This project focused on developing a telerobotic interface that enables a remote human operator to perceive the sense of touch experienced by a robotic hand. The system consisted of a sensorized tactile glove, a haptic glove, and an interface connecting the two.
- Tactile glove: Developed a fabric-based tactile sensor array integrated with a robotic hand to measure pressure applied by external objects.
- Haptic glove: Developed a wearable haptic interface designed to render and replicate the sense of touch for a remote operator.
- Interface: Developed a first-generation interface that mapped the pressure measured by the sensorized robotic hand to equivalent vibratory feedback on the haptic glove worn by the user.
The interface enabled the intensity of the vibration experienced by the remote operator to vary according to the pressure applied to the robotic hand, providing a tactile feedback mechanism for interacting with distant and inaccessible environments.

Authors
Robotics Engineer & Researcher
Robotics engineer and researcher with 10+ years of experience specializing in robotics and computer vision.