Pattern Recognition-Based Prosthetic Arm
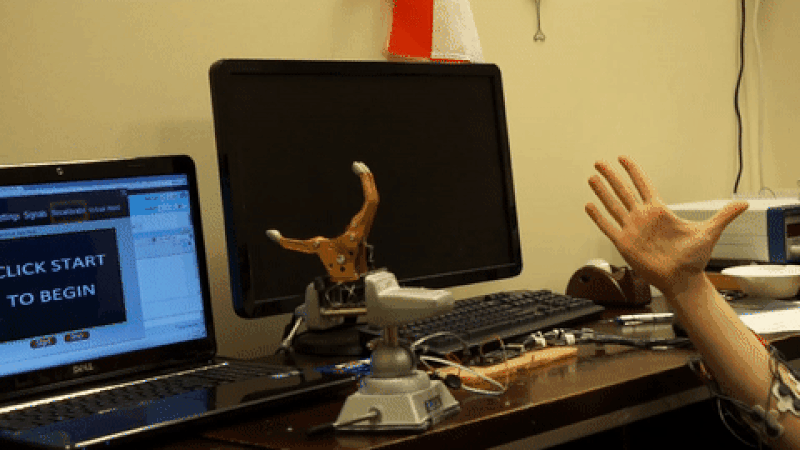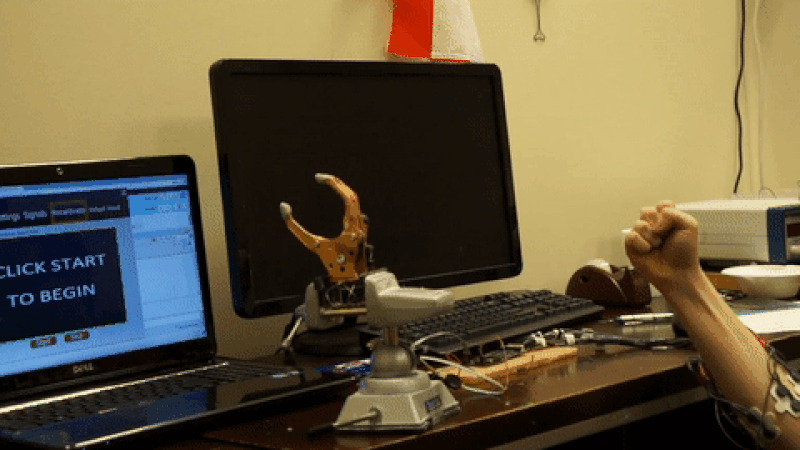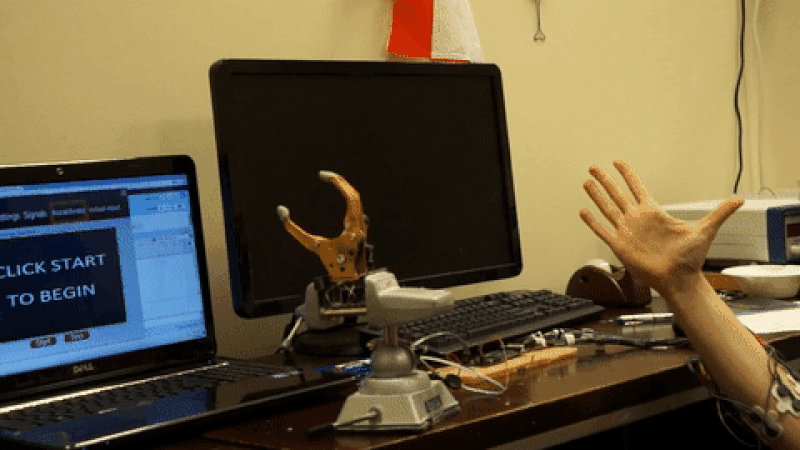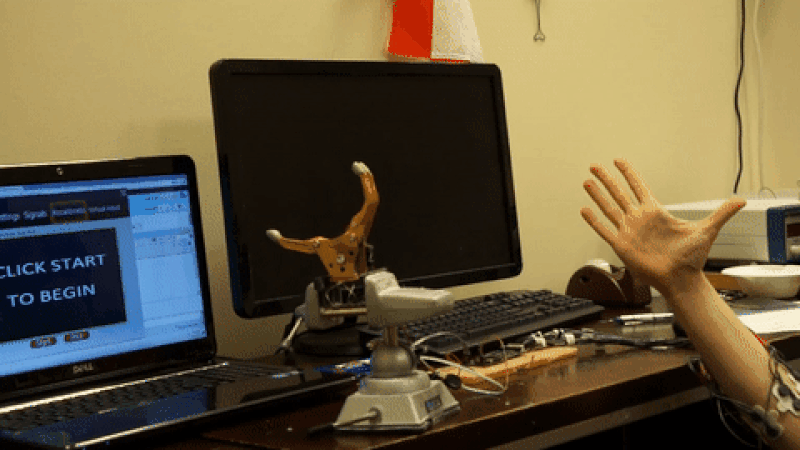
EMG-based pattern recognition for real-time prosthetic hand control.
•
1 min read
EMG-based pattern recognition for real-time prosthetic hand control.
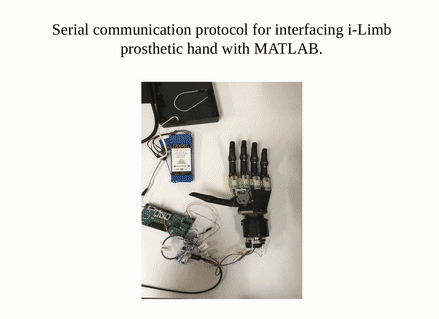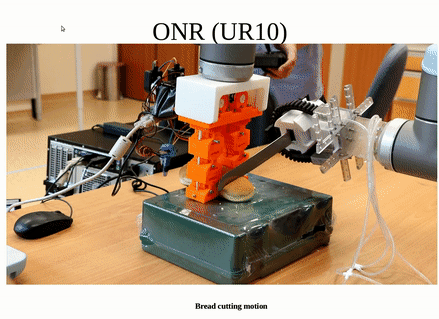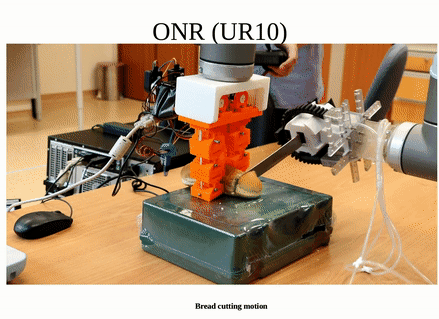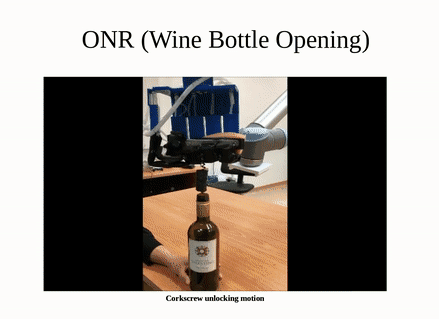
Motion planning and control for robotic manipulation and hand control.
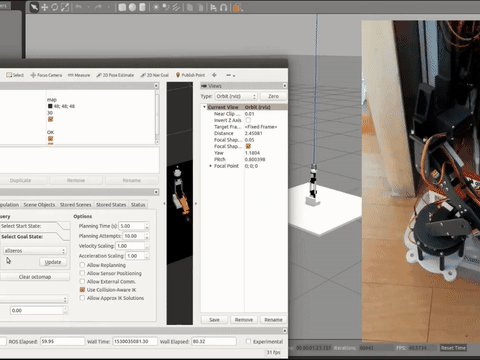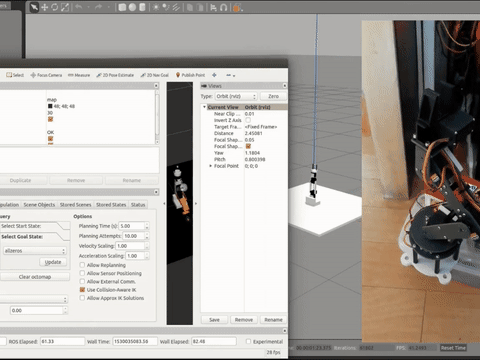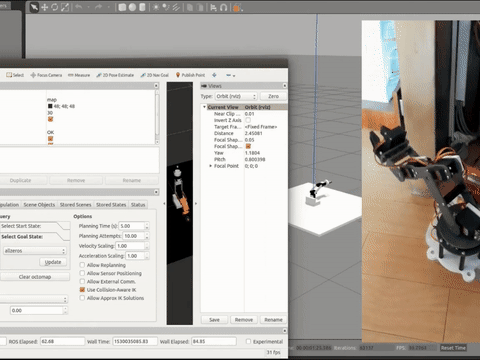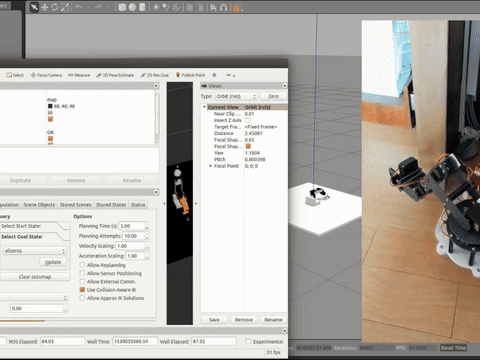
Robotic manipulator control and grasping for autonomous beach cleaning.
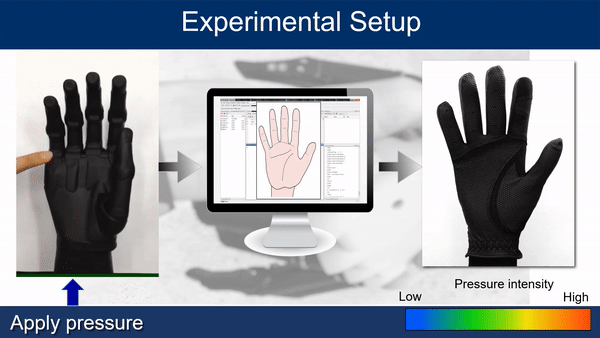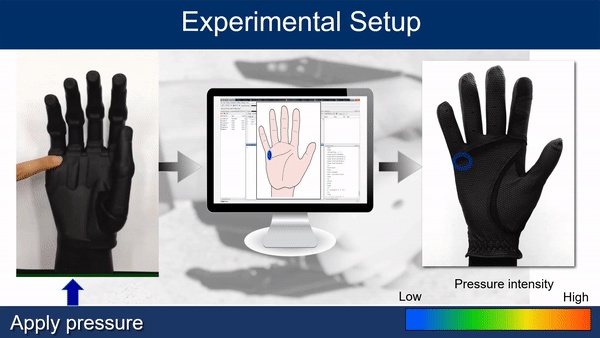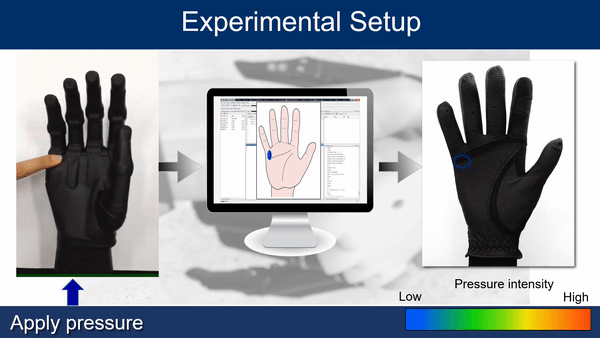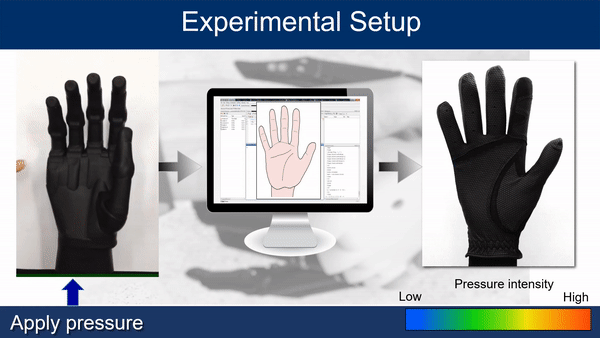
Tactile-to-haptic interface for telerobotic touch feedback.

Sensor fusion and LiDAR-based obstacle avoidance for autonomous ground robots.
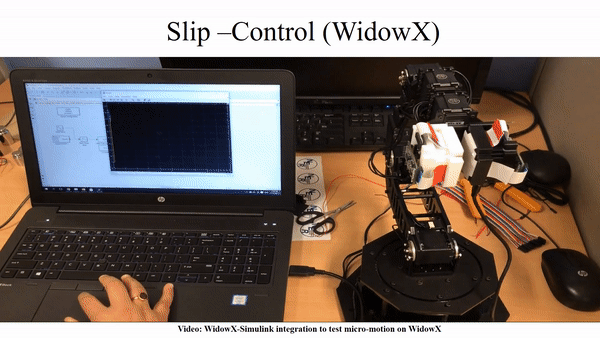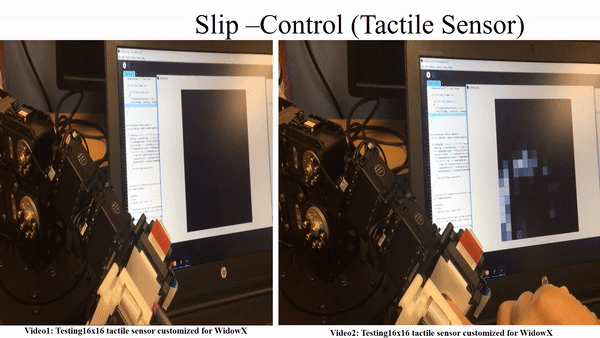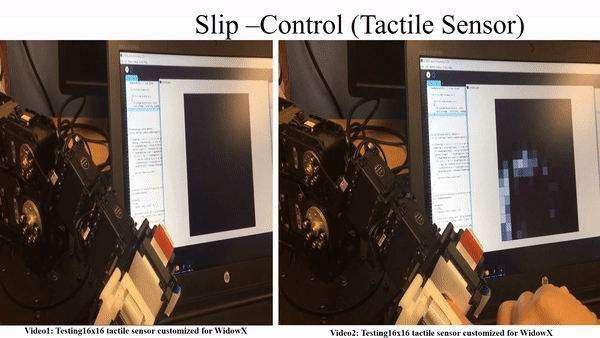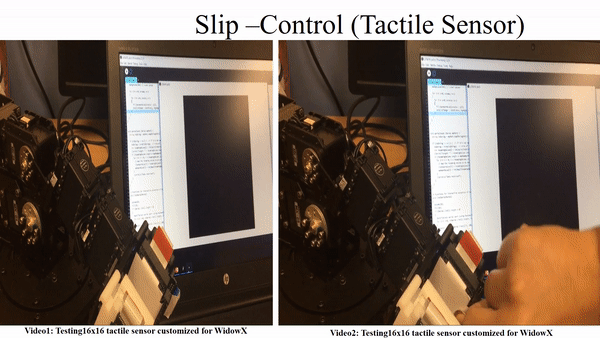
Tactile-sensor-based slip detection and grip control for robotic grasping.
Vehicle-aware path planning and obstacle avoidance for multi-robot patrolling.